Language-Grounded Force/Torque Pretraining for Extrinsic Contact Perception
arXiv:2610.39314 (preprint) · October 2026
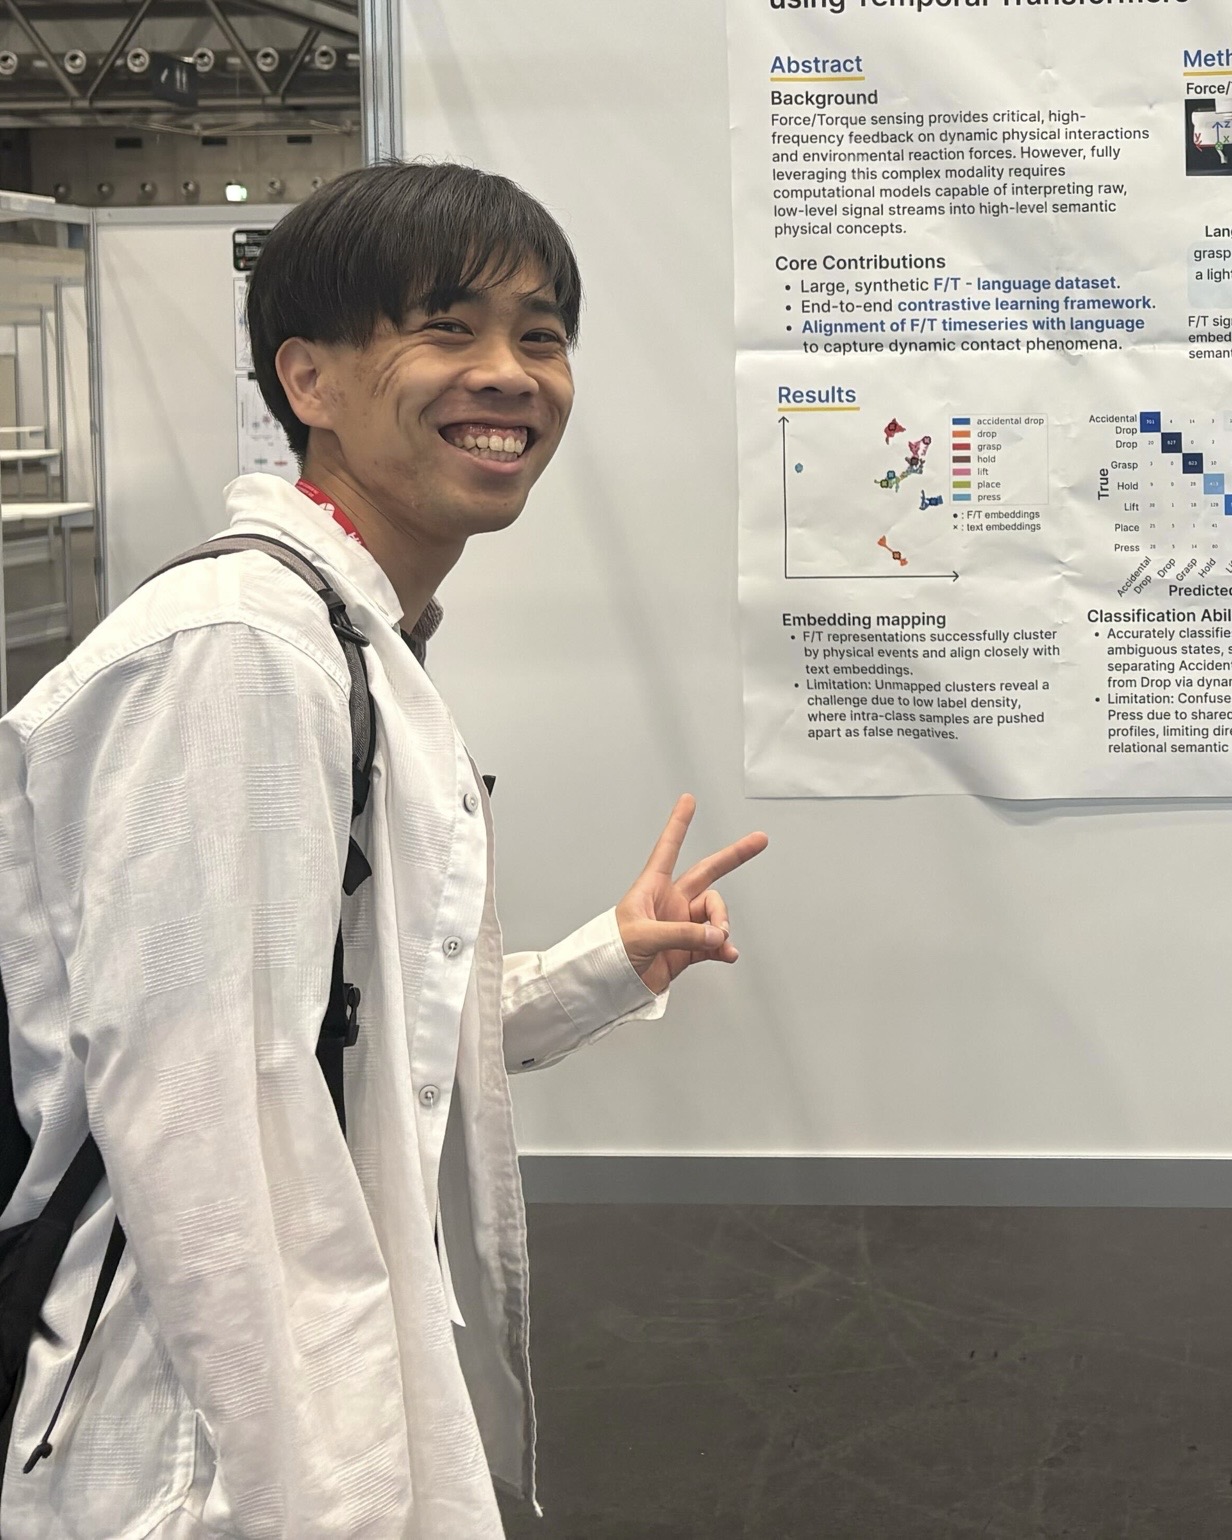
髙橋 和希
Master’s student
Department of Electrical Engineering
and Information Systems
The University of Tokyo
I am a master’s student in the Department of Electrical Engineering and Information Systems at the University of Tokyo, working in the Kawahara Laboratory. I also work as a research assistant (卓越RA) in the laboratory.
I entered the University of Tokyo’s Natural Sciences I program in 2022 and graduated from the Department of Electrical and Electronic Engineering, Faculty of Engineering, in 2026.
My research focuses on force and tactile sensing for robot manipulation. I study representation learning that connects force time series with language, contact-state recognition, and the integration of force information into vision-language-action (VLA) models.
arXiv:2610.39314 (preprint) · October 2026
IEICE Society Conference 2026, B-15-53 · September 2026
DICOMO 2026, 8A-2, pp. 2074–2082 · June 2026
Excellent Presentation Award / Excellent Paper Award
DICOMO 2026, 1F-5, pp. 226–233 · June 2026
ICRA 2026 RoboTac Workshop · June 2026
NeurIPS 2026 2nd Workshop on Agentic AI Benchmarks and Applications for Enterprise Tasks · 2026
The 43rd Annual Conference of the Robotics Society of Japan, 1M4-05 · August 2025
DICOMO 2026 Excellent Paper Award Details
Contact-state recognition using force and tactile information for safe task execution by assistive robots.
DICOMO 2026 Excellent Presentation Award Details
Contact-state recognition using force and tactile information for safe task execution by assistive robots.